Hierarchical Graph-Attentive Multi-Agent Reinforcement Learning for Resilient UAV Swarm Surveillance in Adversarial Environments
Keywords:
UAV swarm coordination, multi-agent reinforcement learning, graph attention network, world model planning, resilient aerial surveillance, fault-tolerant systems, Dec-POMDP.Abstract
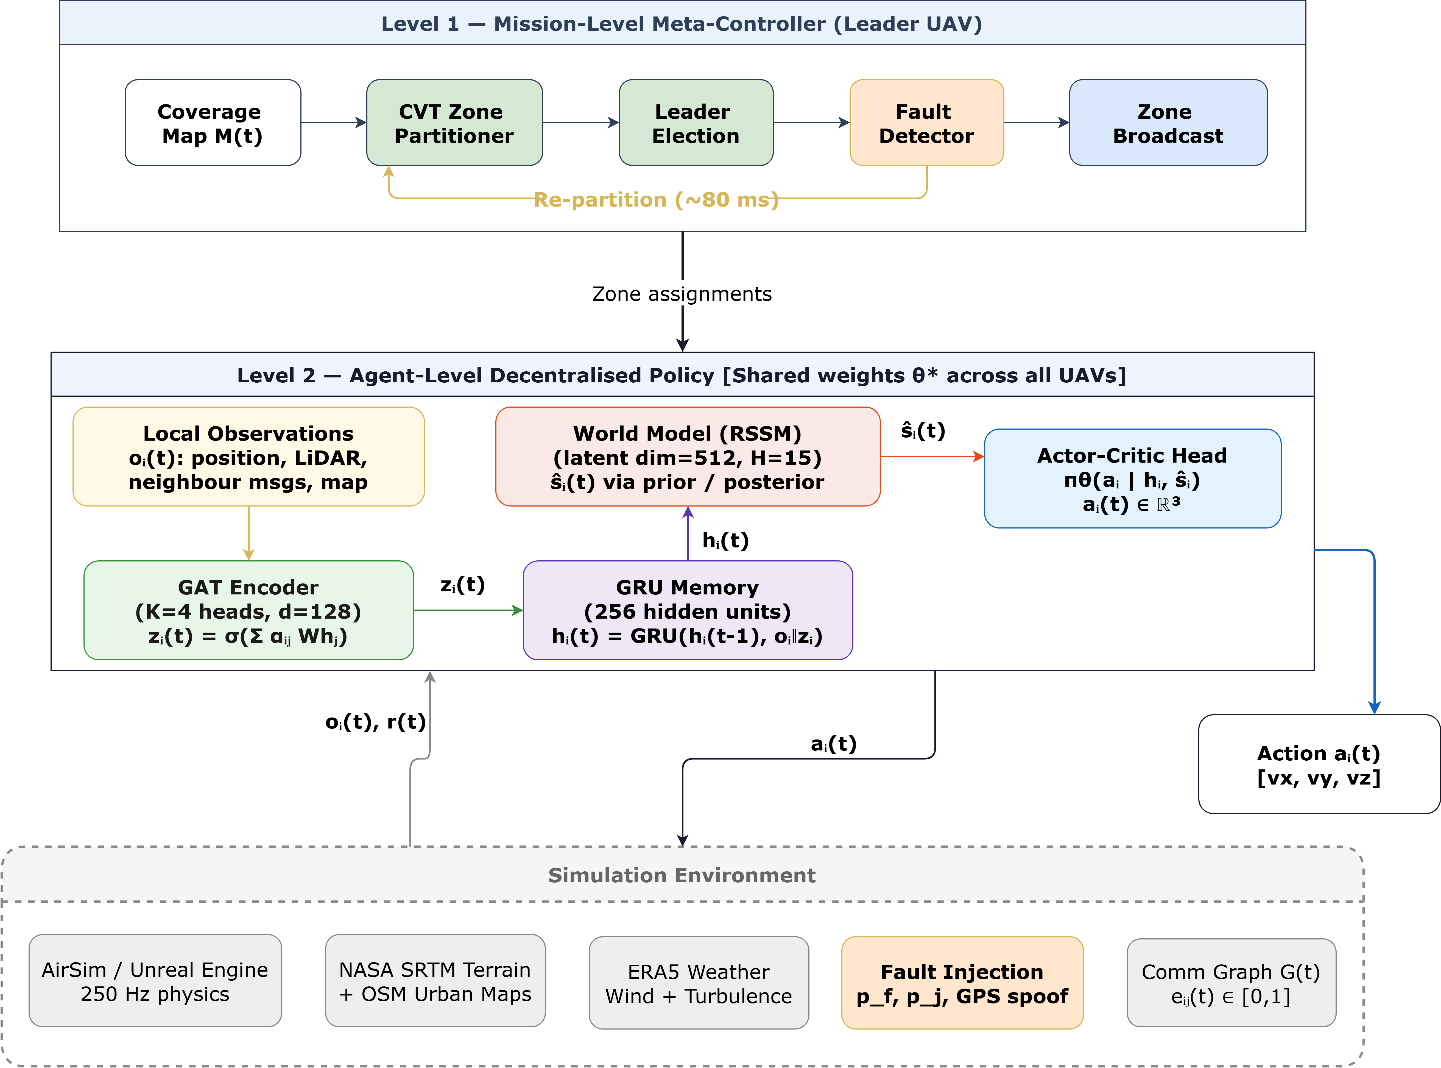
The concept of unmanned aerial vehicle (UAV) swarms, with their distributed sensing, operational redundancy and increased area coverage, can provide a promising solution to large-scale aerial surveillance. While coordinated surveillance in dynamic settings with multiple agents experiencing simultaneous node failures, communication jamming and GPS spoofing is required, existing flat cooperative reinforcement learning frameworks are insufficient to provide adaptive coordination mechanism for this. In this context current multi-agent reinforcement learning approaches have three main drawbacks: exponential growth of the joint-action shape to achieve scalability, topology-blind communication to cope with time-varying changes in the graph due to faults, and purely reactive decision making, which fails when the communication becomes unstable. This paper proposes the Hierarchical Graph-Attentive Multi-Agent Reinforcement Learning with World Model Planning (H-GAT-MARL-WM) framework, integrating four components: a hierarchical Centroidal Voronoi Tessellation-based policy decomposition for scalable task assignment, a Graph Attention Network encoder for topology-aware communication, a per-agent Recurrent State Space Model for imagination-based planning under communication dropout, and a four-stage adversarial curriculum training pipeline. Evaluated across 200 zero-shot episodes under concurrent 20% UAV failure, 30% packet loss, and GPS spoofing with N = 16 agents, the proposed framework achieves 87.6% mean area coverage rate surpassing MAPPO by 16.2 percentage points a mean time to recovery of 21.3 seconds, a Scalability Efficiency Index of 0.91 at N = 24, and a decentralisation gap of 6.8% relative to a centralised oracle. These results establish H-GAT-MARL-WM as a scalable, fault-resilient, and communication-robust framework for autonomous UAV swarm surveillance, advancing the state of the art in decentralised multi-agent coordination for safety-critical aerial applications
Downloads
Published
Issue
Section
License

This work is licensed under a Creative Commons Attribution-NonCommercial 4.0 International License.
This work is licensed under a Creative Commons Attribution-NonCommercial 4.0 International License. You are free to share and adapt the material, but only for non-commercial purposes. You must give appropriate credit to the author(s).